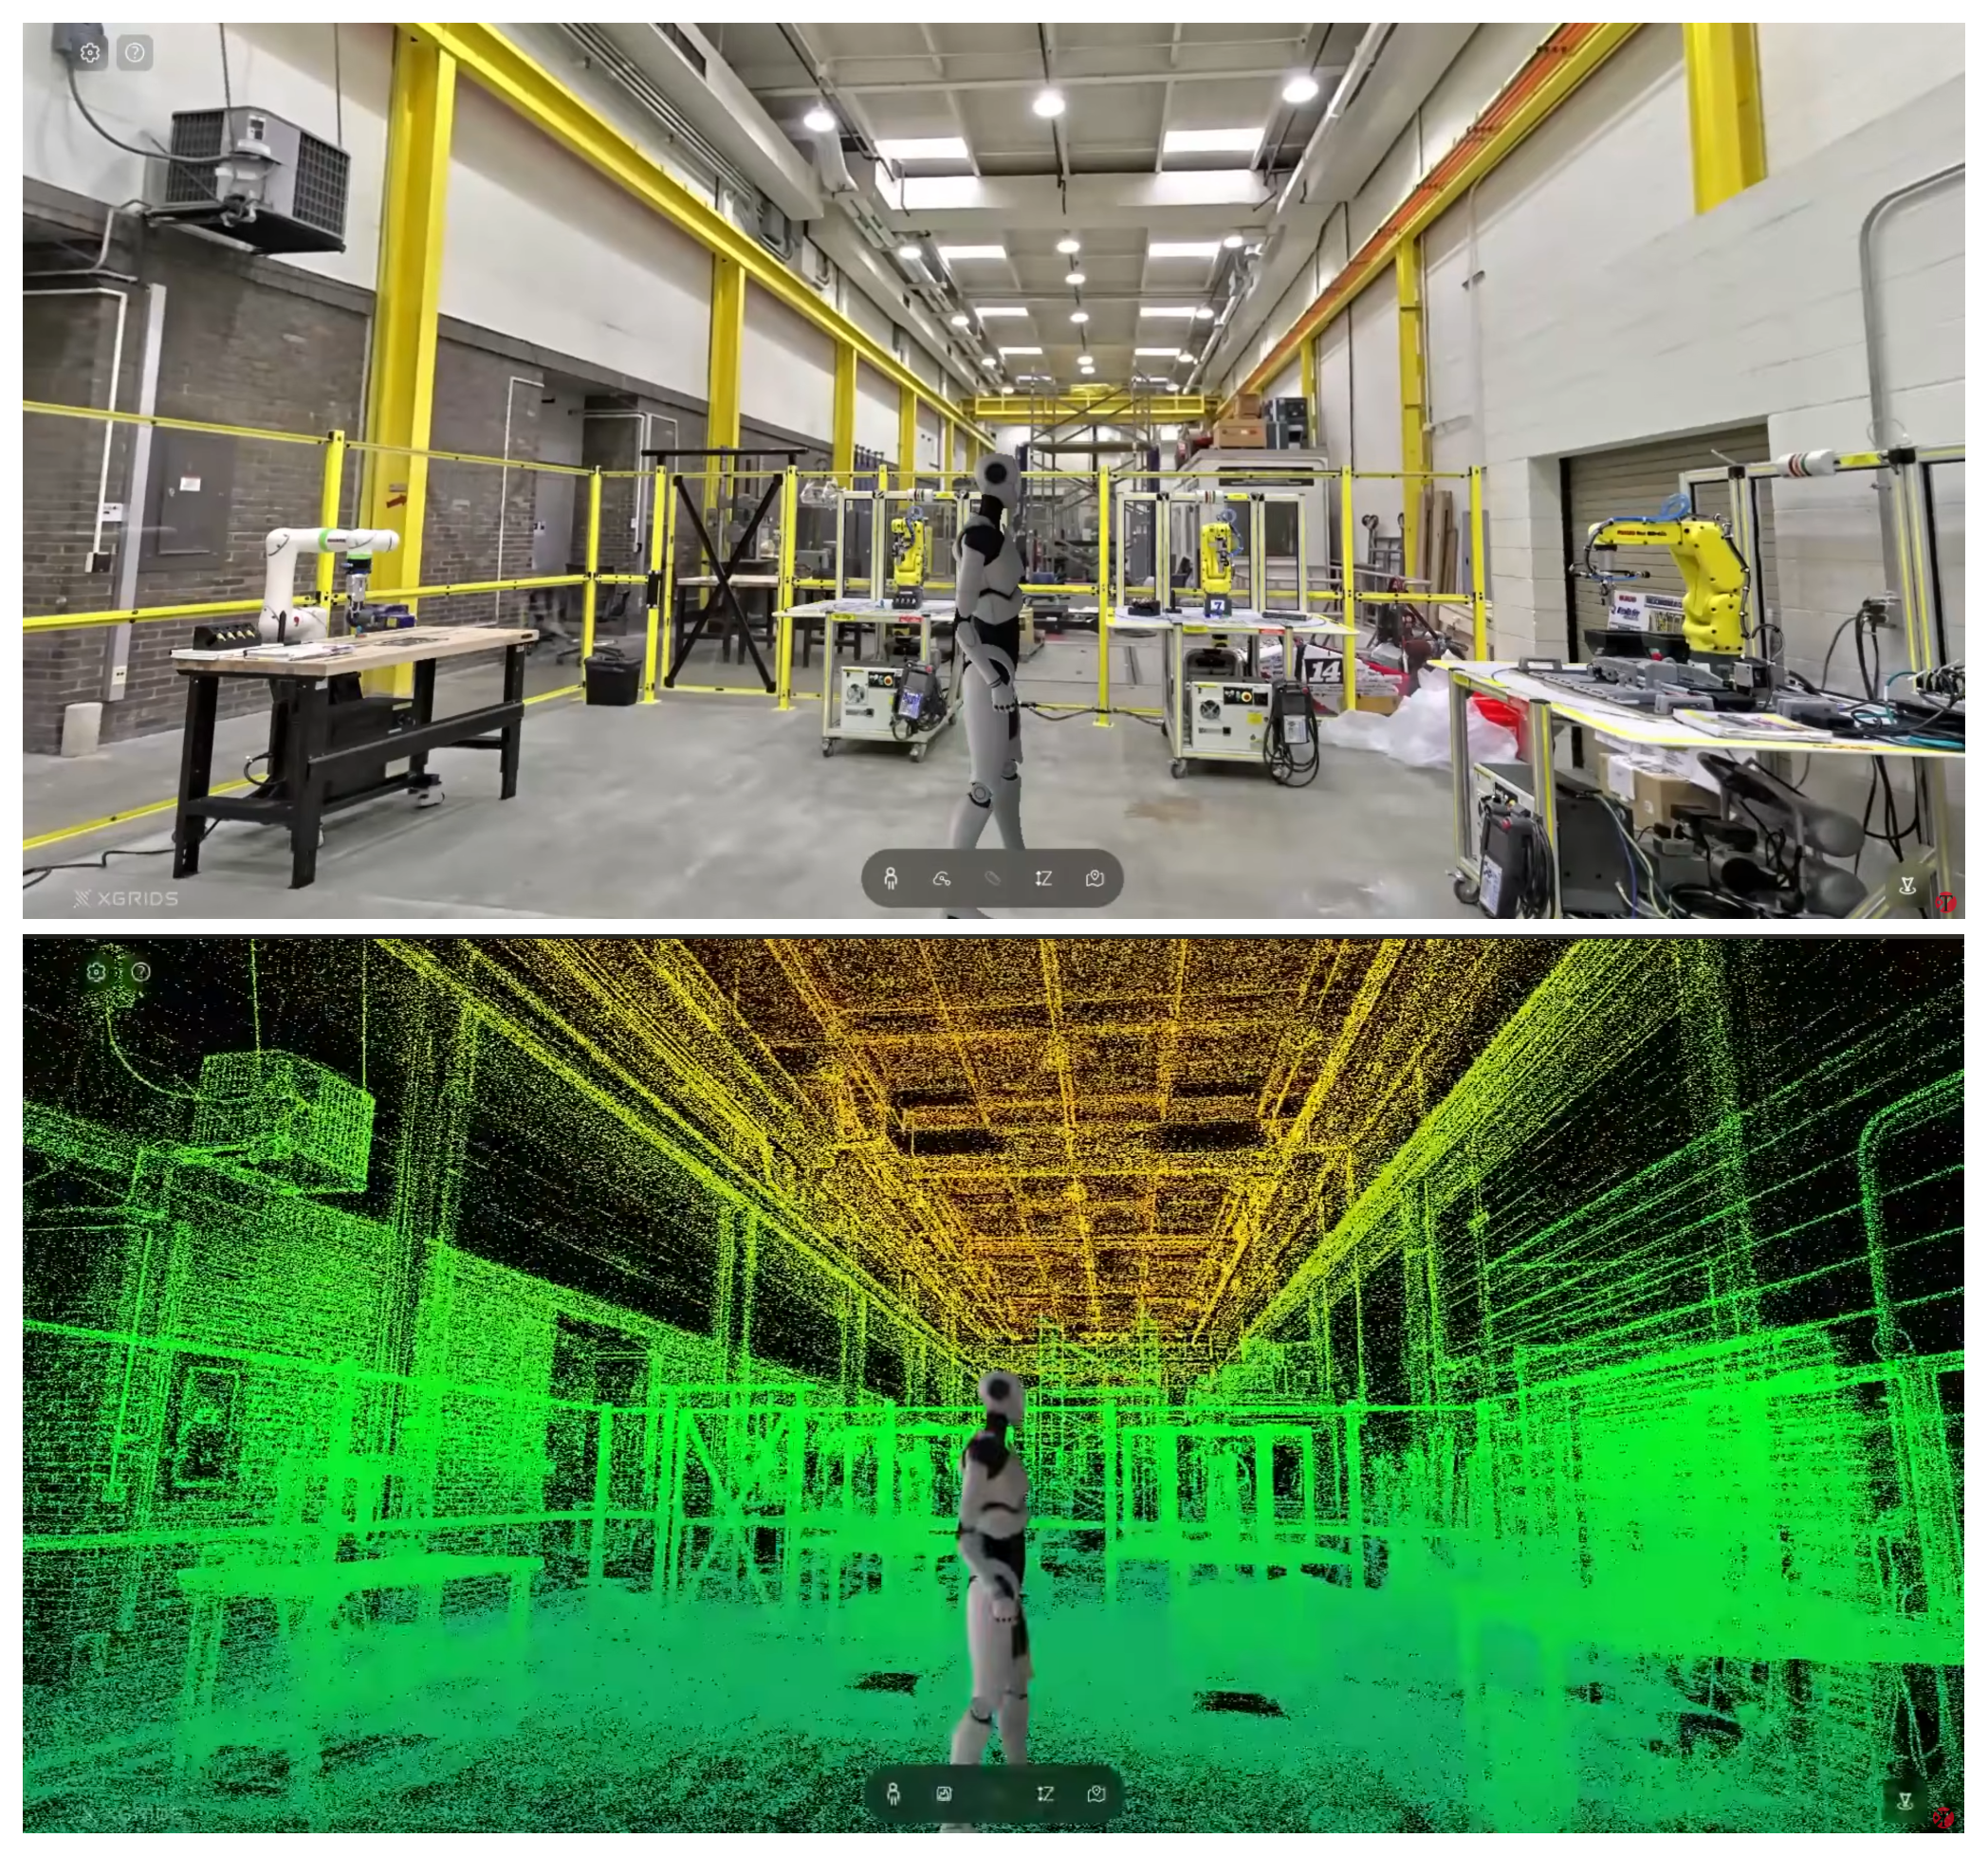
Hyper-realistic environment digital twin for human–robot collaboration
Watch this Youtube Video: https://lnkd.in/gWXTQcbE
This environment scan captures the layout, equipment, and geometry of our robotics workspace. It provides the geometric foundation for the Environment Digital Twin in our HER (Human–Environment–Robot) digital twin framework.
Our framework connects three complementary digital twins:
🔹 Human Digital Twin — representing human motion, behavior, and interactions.
🔹 Environment Digital Twin — representing workspace geometry, equipment, and spatial constraints.
🔹 Robot Digital Twin — representing robot motion, capabilities, and operating states.
Connecting these three components creates a shared context for understanding how people and robots interact within a physical workspace. Our goal is to support simulation, motion planning, and safety assessment as those interactions evolve.
This scan is an important step toward a framework where human behavior, environmental constraints, and robot actions can be considered together to enable safer, more adaptive collaboration.